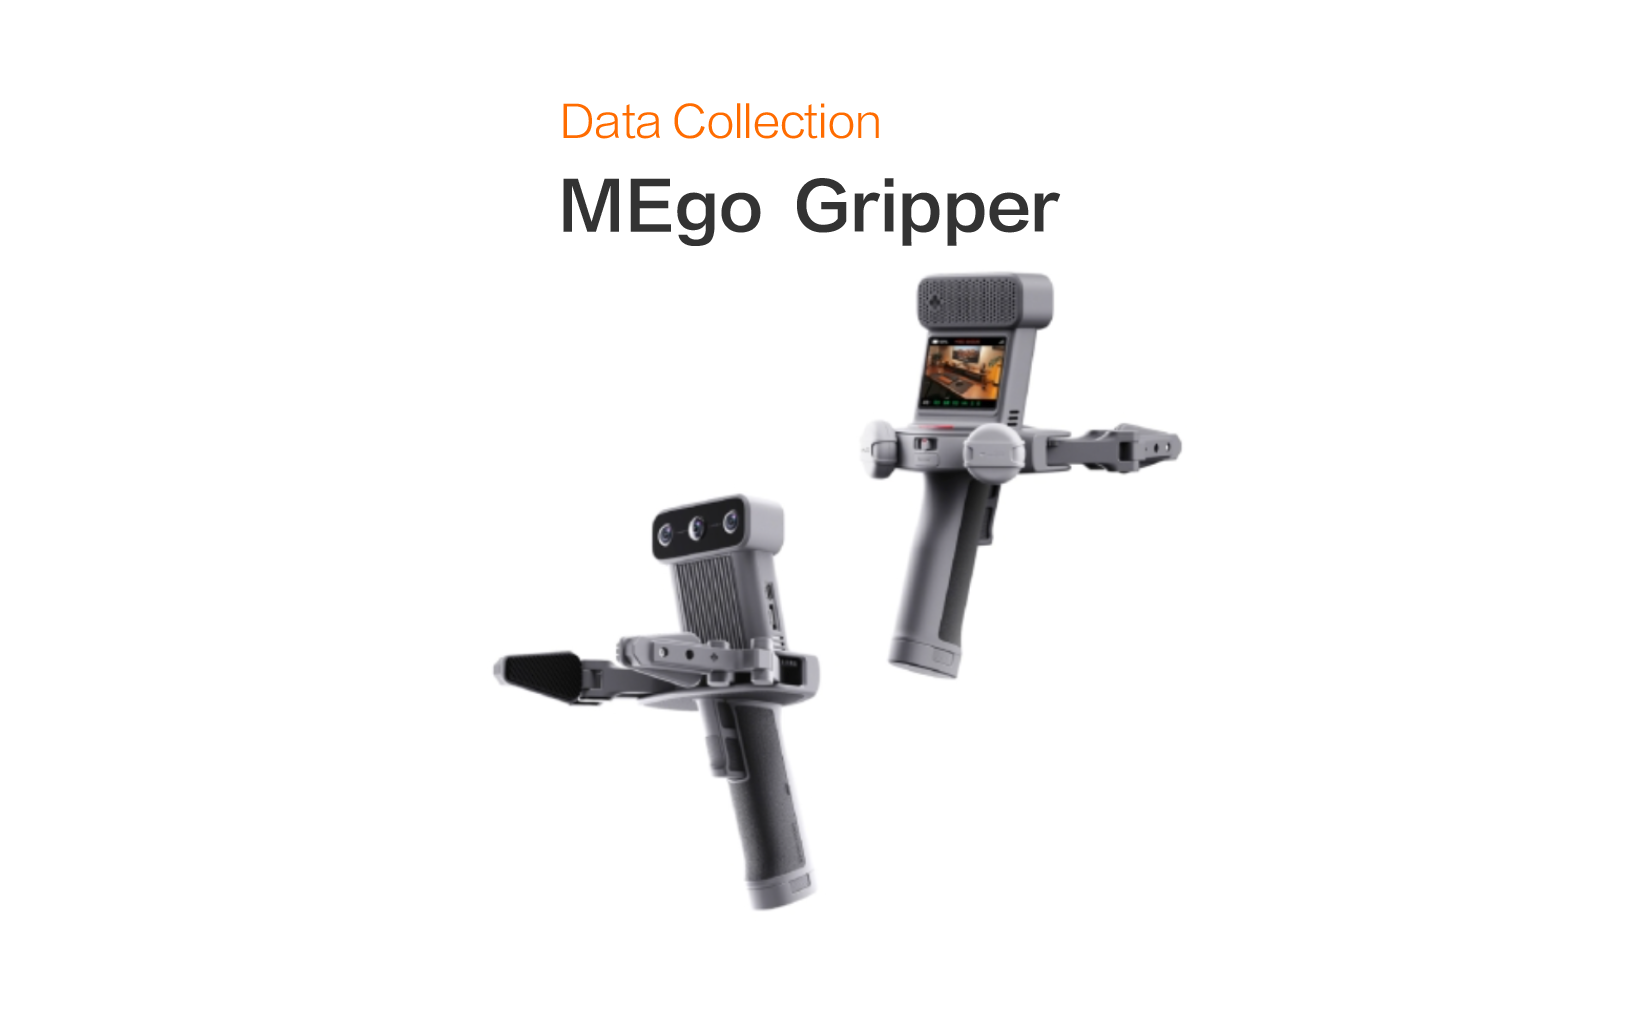
MEgo-Gripper is a high-precision data acquisition gripper purpose-built for robotic arm end-effectors. Leveraging a multimodal visual-inertial fusion algorithm, it achieves ≤1 mm end-effector spatial positioning accuracy, while full-channel 1080P@60fps HD visual streams fully capture physical interaction details; sub-millisecond global synchronization precisely aligns data from vision, tactile, pose, and other sensors; with an ultra-lightweight design of only 480 g and a quick-swap battery solution, it is cable-free and supports field data collection; paired with an end-to-end cloud data engine, it provides one-stop trajectory reconstruction, quality inspection, and intelligent annotation, delivering high-fidelity, full-scenario, high-quality collected data for Physical AI training.
| Core Specifications | |
| Basic Information | Sensor Specifications |
| Weight: 480g | Fisheye lens field of view (FOV): 200° |
| Battery life: 3 hours (quick-swap supported) | IMU frame rate: 500 Hz |
| Storage: 256 GB TF card | Tactile array spatial resolution: 1 mm |
| Video: 1080P@60fps | Exposure mode: Global shutter |
| Communication: Wi-Fi 6, USB 3.1 | IMU type: Automotive-grade 9-axis |
| Synchronization: Multi-device wireless time synchronization (1 ms) | |
| Trajectory accuracy: Spatial positioning accuracy 1 mm | |
| Output Data Information | |
| Triple-camera RGB images | |
| Depth information | |
| IMU (Inertial Measurement Unit) data | |
| Spatial positioning trajectory | |
| Microphone audio | |
| Tactile information | |
| Gripper angle | |
| Gripper opening distance | |