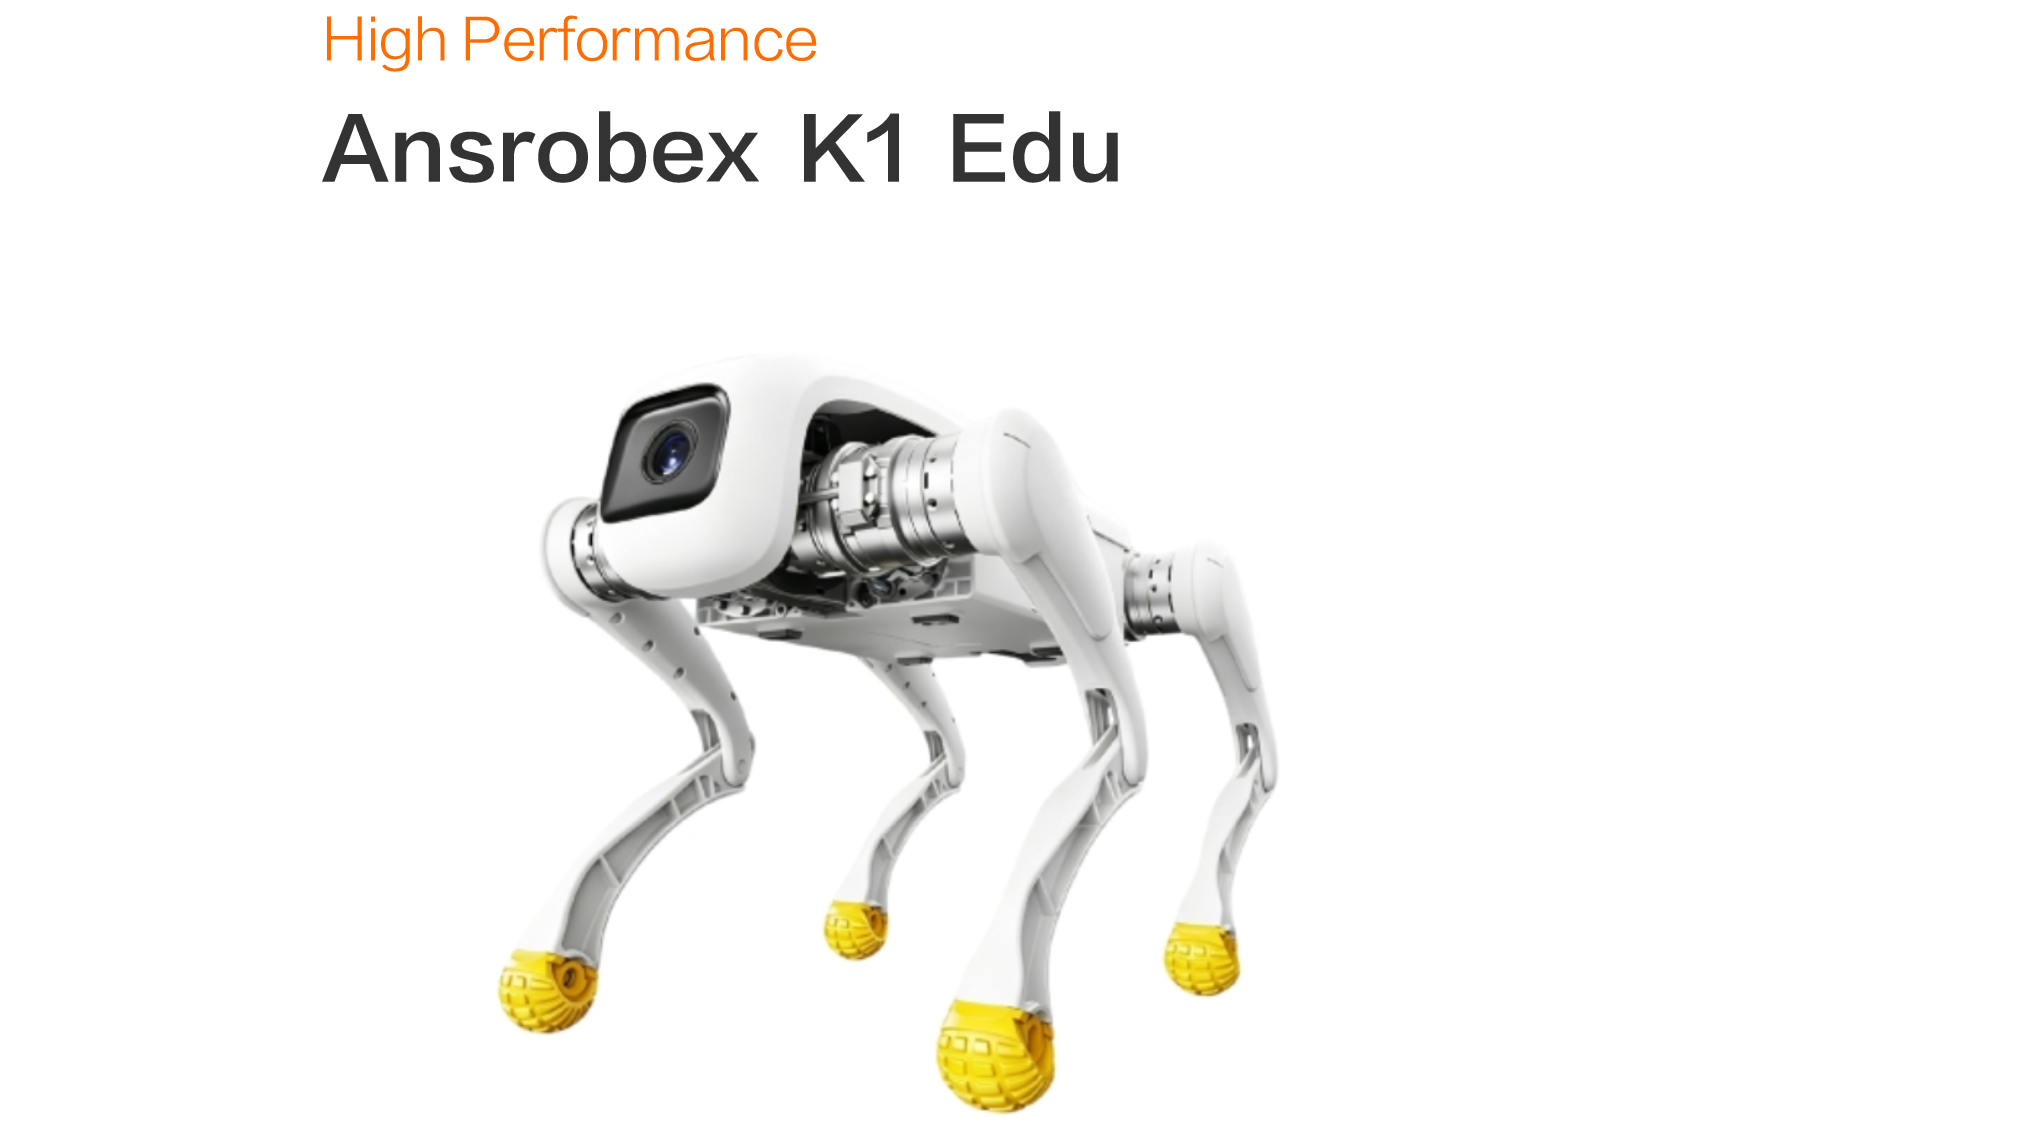
High dust and water protection levels, capable of handling splashes, moisture, mud, and dusty environments with ease. Aluminium alloy vacuum die-casting process featuring a lightweight structural design. Core components treated with sealed protection and anti-corrosion treatment.
RL-based gait control, enabling adaptability to complex terrains and diverse ground surfaces, with self-balancing, anti-tipping, and disturbance rejection capabilities. Max running speed: 3.7 m/s. Max climbing angle: 40°. Forward or upward jump height: 35 cm. Continuous stair-climbing height: 16 cm.
Peak torque of 48 N·m delivering high torque output for complex terrains and high-load operations. Validated through millions of impact tests, ensuring long module lifespan, strong impact resistance, and suitability for high-intensity multi-scenario applications. Equipped with a dual-encode controller, eliminating the need for zero-position calibration and enabling immediate operation upon startup.
Standardized interfaces support integration with various payload modules for multi-scenario application development. Open SDK for secondary development, supporting upper payload integration. It is compatible with positioning modules, LiDAR, depth cameras, RTK modules, 4G/5G modules, image transmission modules, and other peripherals. It also provides URDF modeling files, supporting debugging and operation in Isaac-sim and Mujoco simulation environments. The intelligent following function requires user secondary development.
| Specification | |
| Basic Information | Performance Parameters |
| Material: Aluminum alloy + high-strength engineering plastic | Base Computing: 8-core high-performance CPU |
| Standing Dimensions (L × W × H): 635 mm × 360 mm × 420 mm | Max Working Power: 3,500 W |
| Prone Dimensions (L × W × H): 675 mm × 435 mm × 145 mm | Max Speed: 3.5 m/s |
| Total Weight (including battery): 15.5 kg | Rated Payload: 5 kg |
| Operating Temperature: 0°C–40°C | Continuous Stair-Climbing Height: 16 cm |
| Degrees of Freedom: Total 12 DOF, 3 DOF per leg | Max Climbing Angle: 30° |
| Charging Time: Approx. 1 h (10%–90% battery level) | Vertical Jump Height: 35 cm |
| Endurance: Approx. 1–2 h | Sensors |
| Operating Range: 6 ± 1 km | IMU: Standard |
| Joint Parameters | Function List |
| Actuator Type: High power density motion unit | Standard Motions: Standing, prone, damping, pitch posture, high/low posture, horizontal turning |
| Max Joint Torque: 48 N·m | Stunt Motions: Forward jump, upward jump, bipedal standing, backflip, greeting, etc. |
| Aluminum Alloy Precision Joint Motor: 12 units | Real-time Image Transmission: Supported |
| Joint Motion Range (Body): -28° to 28° | Secondary Development: Supported |
| Joint Motion Range (Thigh): -170° to 66° | Functional Expansion Interfaces: Ethernet port, USB port, power interface, SBUS interface, UART interface |
| Joint Motion Range (Calf): 35° to 156° | Accessories |
| Camera FOV: DFOV 122°, HFOV 111°, VFOV 70° | Adapter: Standard |
| Battery | Charging Dock: Standard |
| Nominal Capacity: 5 Ah, Rated Capacity: 4.6 Ah | Handheld Remote Controller: Standard |
| Voltage: 43.2 V | |
| Others | |
| Warranty Period: 1 year | |